Ground truth for trees, not traffic.
A high-resolution, physically based stereo benchmark aimed at individual trees and the forests around them. Where KITTI gave the automotive community dense ground truth for streets, this suite delivers the same rigour for natural geometry — the hard case for every modern 3D-perception pipeline.
Each capture orbits a target tree at multiple elevations (0°, ±45°) with a simulated Stereolabs ZED Mini-class rig, and every frame ships with stereo RGB, metric depth, disparity, world-space normals, instance segmentation and a dense point cloud.
forest_new —
see it full length
A flight through the forest
Alongside the orbits of single trees, we flew a camera through the
whole forest_new scene on one continuous path — 74
seconds, 2220 frames, the same simulated ZED Mini rig. The video
shows four views of that flight at once, all from the same instant
and the same camera, so you can watch the ground truth move with
the picture.
RGB (left eye) ZED Mini sim
The left camera of the simulated stereo rig — the view a drone flying the route would record.
Depth 0 – 65 m
Metric distance to the first surface, false-coloured near to far, with the scale down the side of the pane.
Segmentation: trees live tree-pixel %
Which pixels belong to a tree, counted as the flight goes and shown in the badge.
Disparity fx·B/Z, B = 63 mm
The horizontal shift between the two cameras — the same quantity the capture sets ship per frame.
HD720
1280×720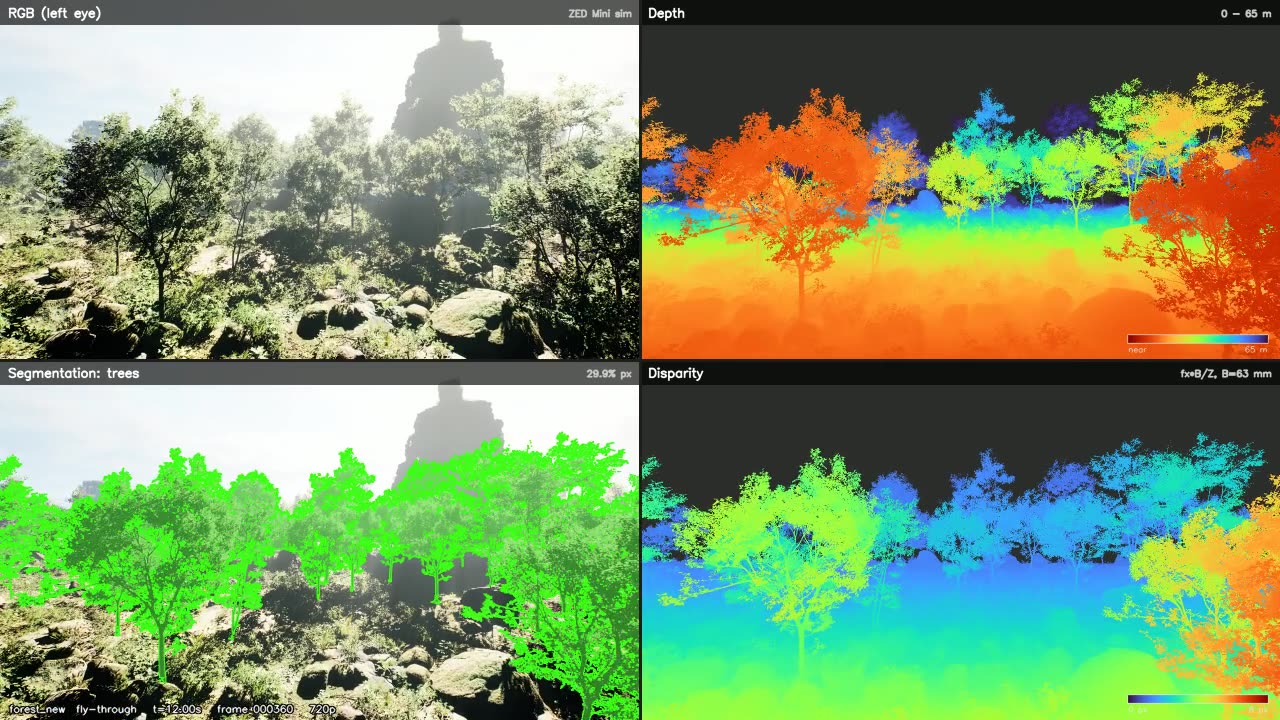
The HD720 encode is not in this checkout — it is
too large to keep in the repository. Rebuild it with
tools/build_site_video.py.
Same output size as the HD720 capture set. This flight was rendered at 2560x1440 and downsampled 2x.
1080P
1920×1080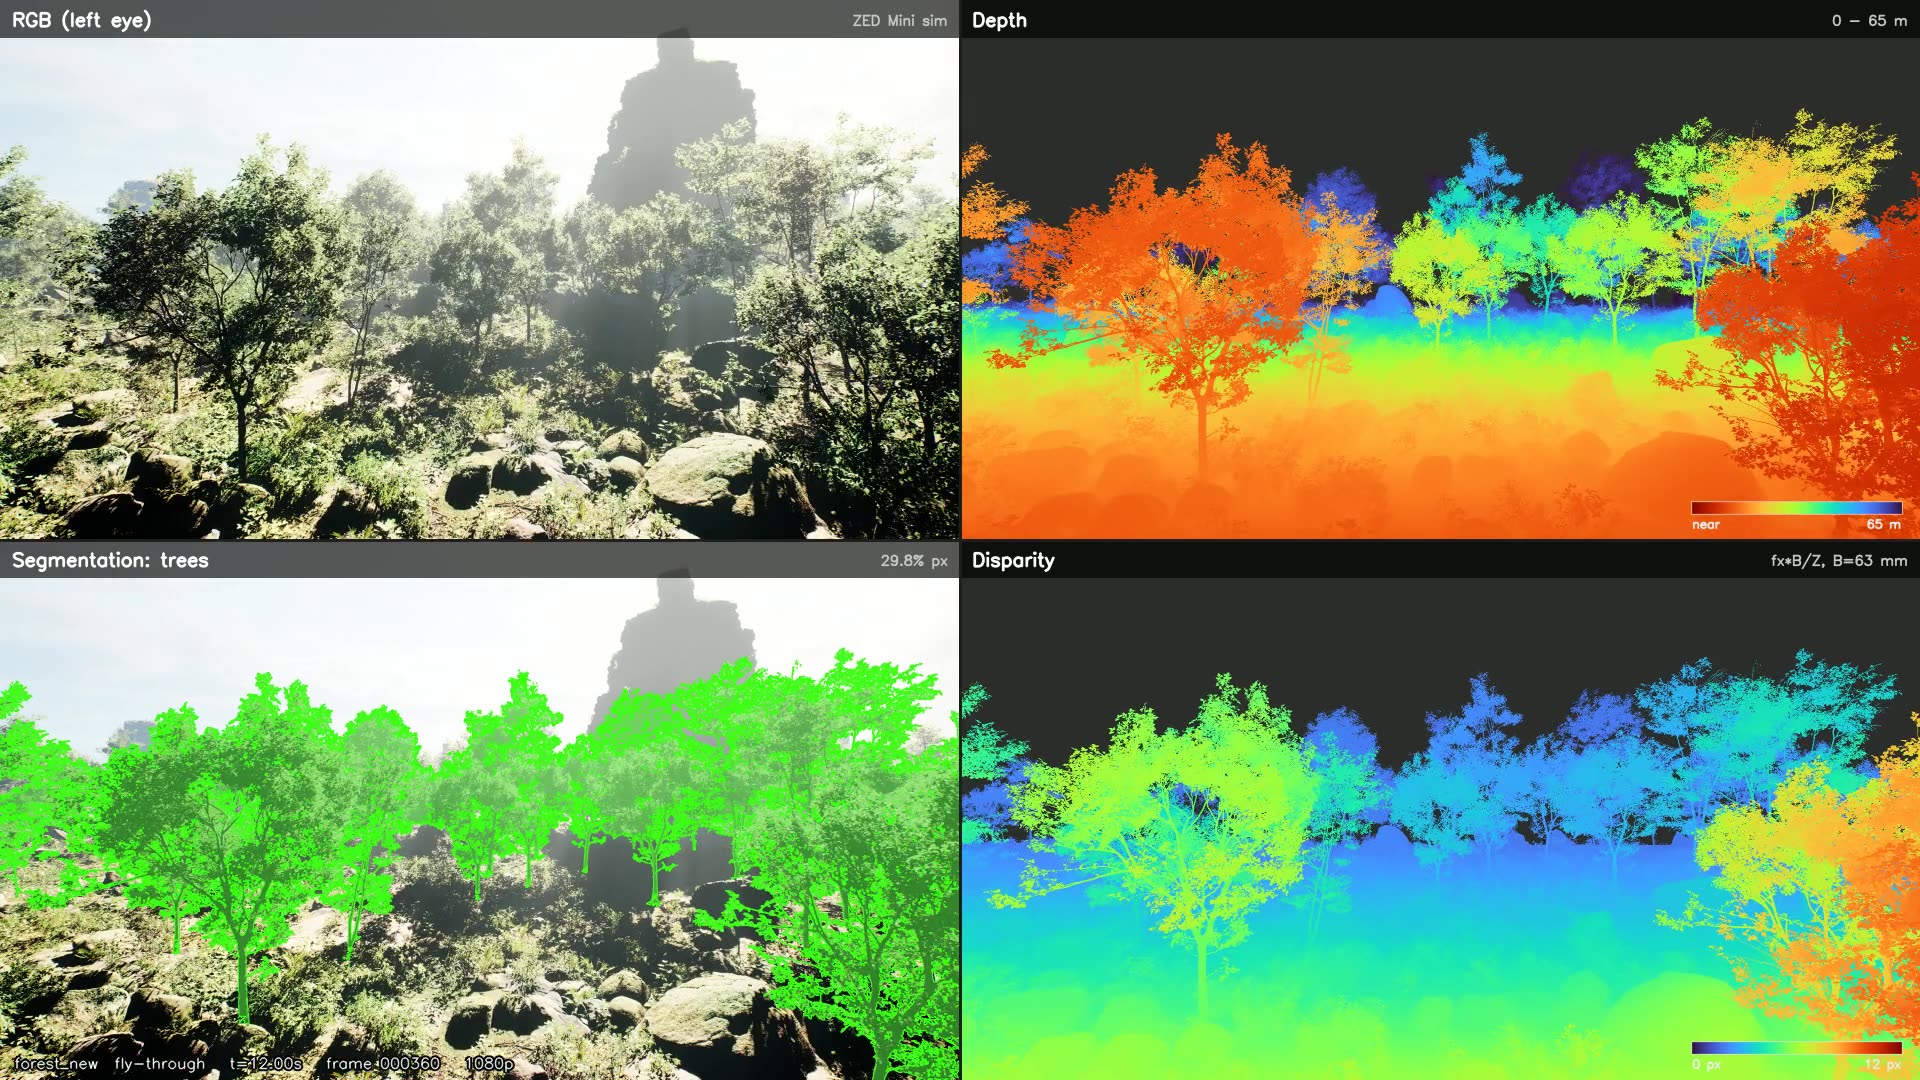
The 1080P encode is not in this checkout — it is
too large to keep in the repository. Rebuild it with
tools/build_site_video.py.
Same output size as the 1080P capture set, though the flight was rendered at 2880x1620 and downsampled 1.5x, while that capture set is native 1920x1080.
Both files are the same flight, re-encoded for the web from masters of 294 MB and 641 MB. Each channel was also kept on its own at full resolution: left and right RGB, depth, segmentation, disparity, and a depth pass covering only the 2500 labelled trees.
Dataset at a glance
What's inside every frame
| Modality | Description |
|---|---|
leftLeft RGB |
Left-camera RGB renderings of the stereo pair. |
rightRight RGB |
Right-camera RGB renderings forming the stereo pair (63 mm baseline). |
left_depthLeft Depth |
Per-pixel metric depth. EXR/NPY and a 16-bit millimetre PNG for ground truth, *_vis.png for preview. |
right_depthRight Depth |
Per-pixel metric depth for the right camera. |
left_disparityLeft Disparity |
Disparity in pixels (left frame), 16-bit PNG and float NPY. |
right_disparityRight Disparity |
Disparity in pixels (right frame). |
left_normalLeft Surface Normals |
World-space surface normals. EXR/NPY for ground-truth, *_vis.png for preview. |
right_normalRight Surface Normals |
World-space surface normals for the right view. |
left_segLeft Instance Segmentation |
Per-instance segmentation: colourised PNG, integer ID PNG, target mask and overlay. |
right_segRight Instance Segmentation |
Per-instance segmentation for the right view. |
left_classLeft Semantic Classes |
Semantic class map: *_class.png holds the integer class per pixel, *_class_color.png is the colourised preview. |
right_classRight Semantic Classes |
Semantic class map for the right view. |
left_labelsLeft Detection Labels |
YOLO annotations for the target tree: normalised polygons in *_labels.txt, boxes in *_labels_bbox.txt. |
right_labelsRight Detection Labels |
YOLO polygons and boxes for the right view. |
pointcloudPoint Clouds |
Dense point clouds (.ply), per frame and/or merged across the orbit, in raw and coloured variants. |
Want to see them side by side? Compare the two worked examples →
Published capture sets
Citation
The paper is on arXiv at https://arxiv.org/abs/2609.13232. If this dataset is useful in your research, please cite:
@misc{Lin2026TreeVision,
  author        = {Yida Lin and Mengjie Zhang and Bing Xue and Richard Green and Sam Schofield},
  title         = {The Tree Vision Stereo Benchmark Suite},
  year          = {2026},
  eprint        = {2609.13232},
  archivePrefix = {arXiv},
  url           = {https://arxiv.org/abs/2609.13232},
  institution   = {Victoria University of Wellington and University of Canterbury},
  note          = {A joint project of VUW ECS and the UC Vision Group}
}
Copyright & licence
All datasets and benchmarks on this site are released for academic, non-commercial use under the Creative Commons Attribution-NonCommercial-ShareAlike 4.0 licence. Please attribute the authors when redistributing or building upon this work.
Privacy
The renderings are produced from synthetic 3D foliage assets and contain no personally identifiable information. We record anonymised page views and download clicks to report dataset reach. If anything published here concerns you, please contact us.