720P example
— example_720, tree390
bundled example
This is the raw file listing. For a guided tour with every modality rendered
side by side, see the
example walkthrough.
Camera
- Camera model
- Stereolabs ZED Mini (simulated, HD720)
- Resolution
- 1280×720 px
- Baseline
- 63.0 mm
- Focal length
- 2.1 mm
- Sensor width
- 4.2 mm
- Field of view (H)
- 90.0°
Capture
- Camera distance
- 2.0–4.0 m to the trunk surface
- Orbit sweep
- 356.0°
- Elevation rings
- 0°, 45°, -45°
- Depth range
- 0.1 – 15.0 m
- Planned captures
- 48
- Frames on disk
- 3
- Files / size
- 88 · 66.0 MB
- Semantic classes
- 11
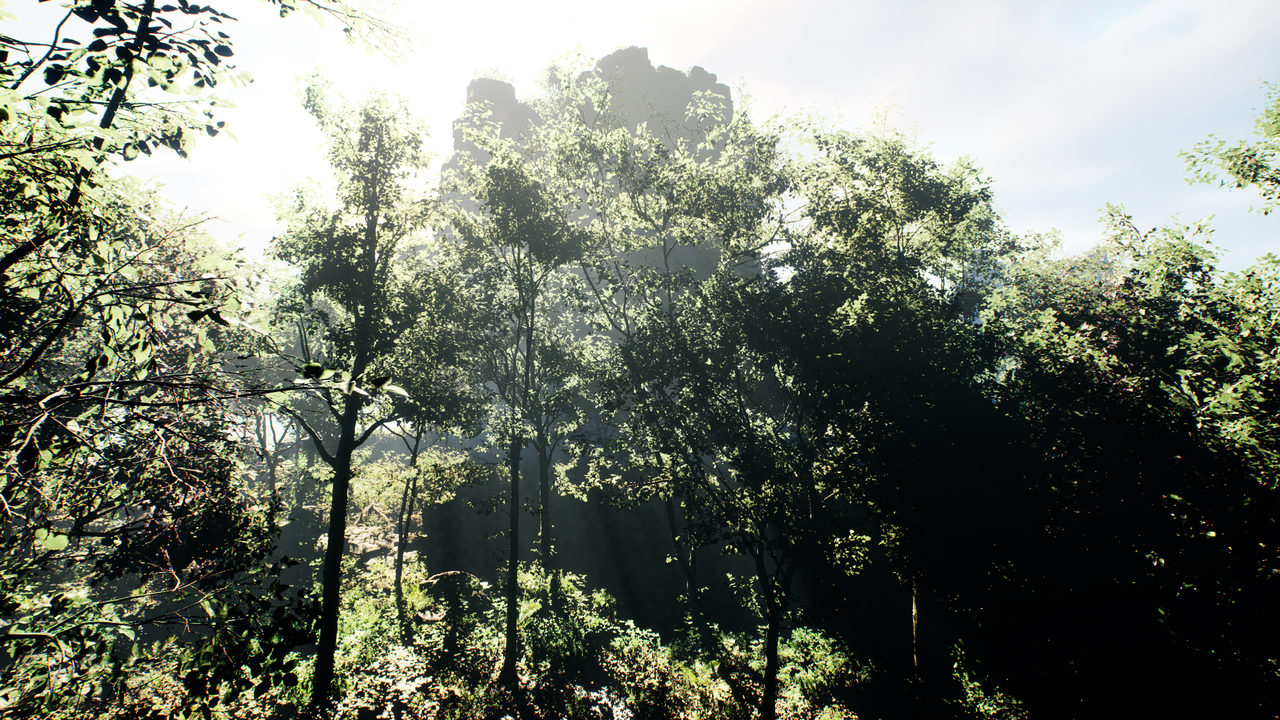
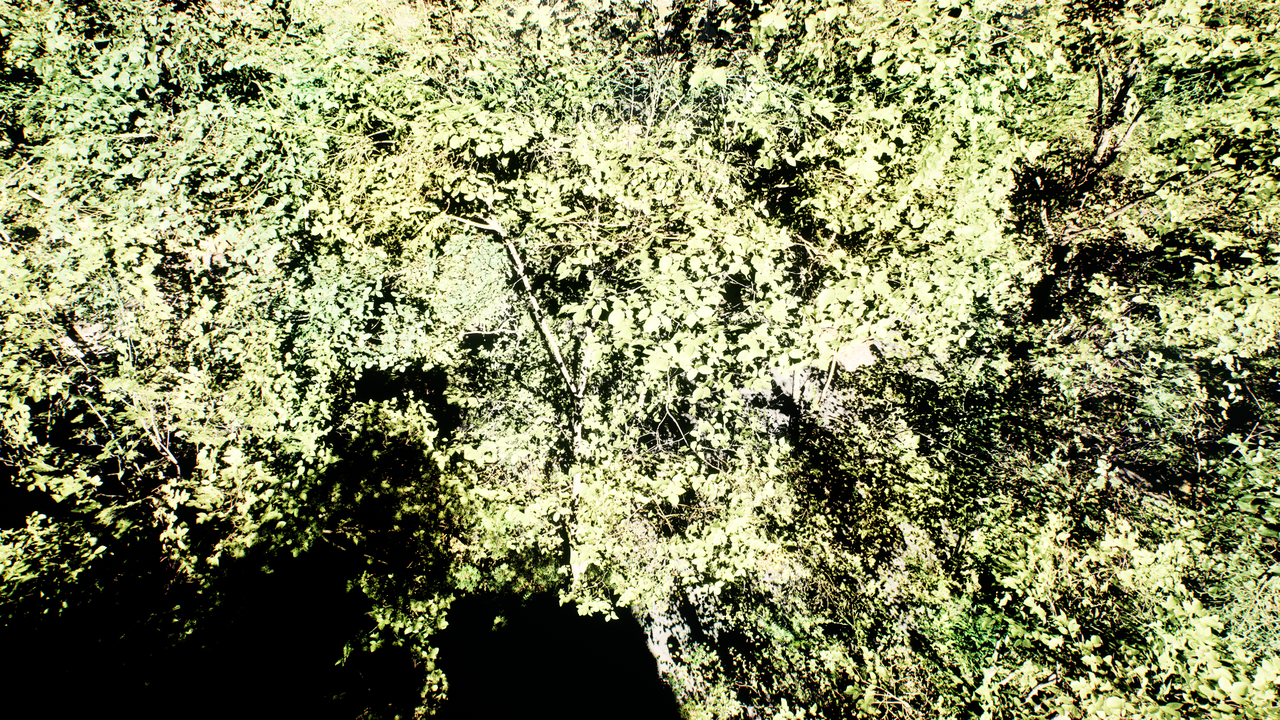
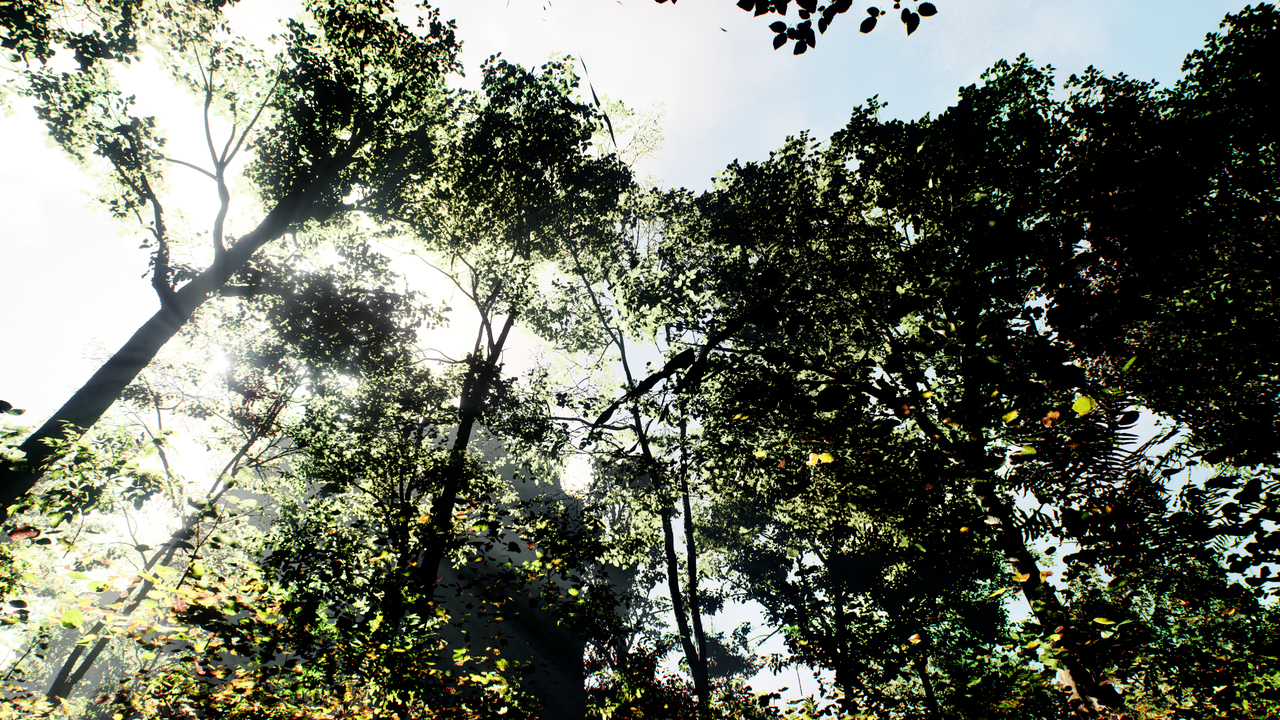
Left RGB / left 3 files · 5.8 MB
Left-camera RGB renderings of the stereo pair.
All 3 files
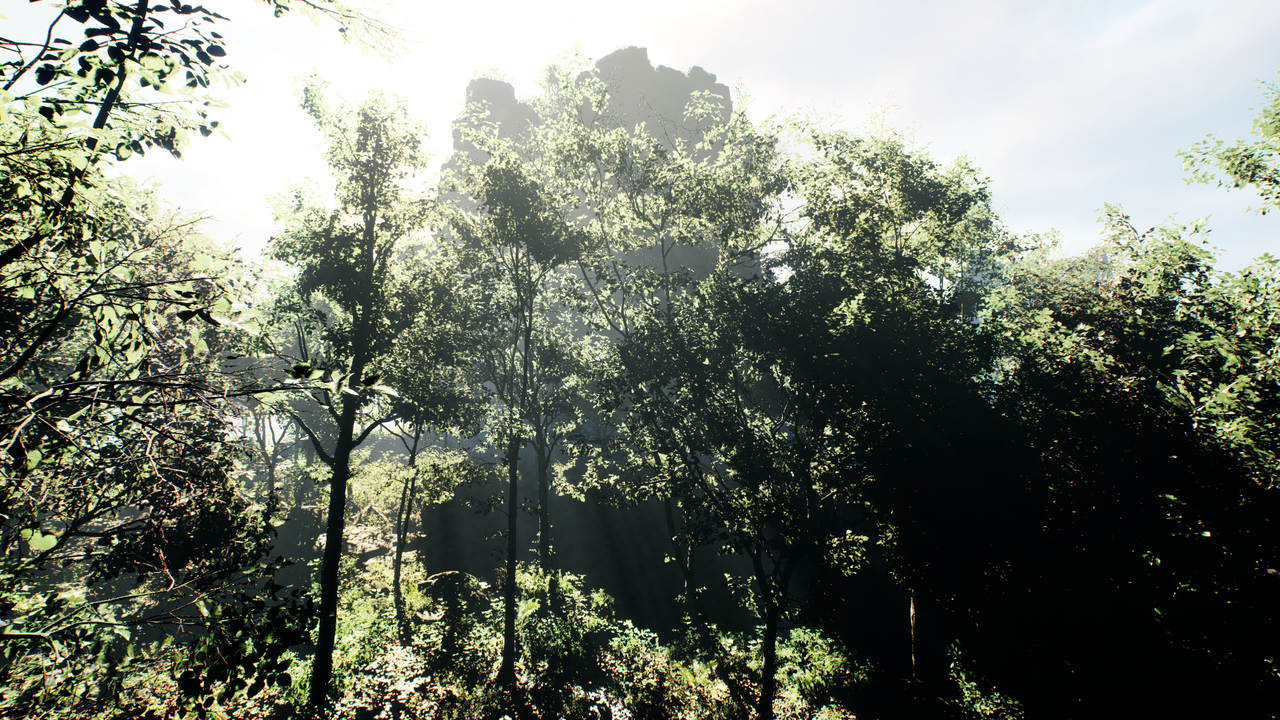
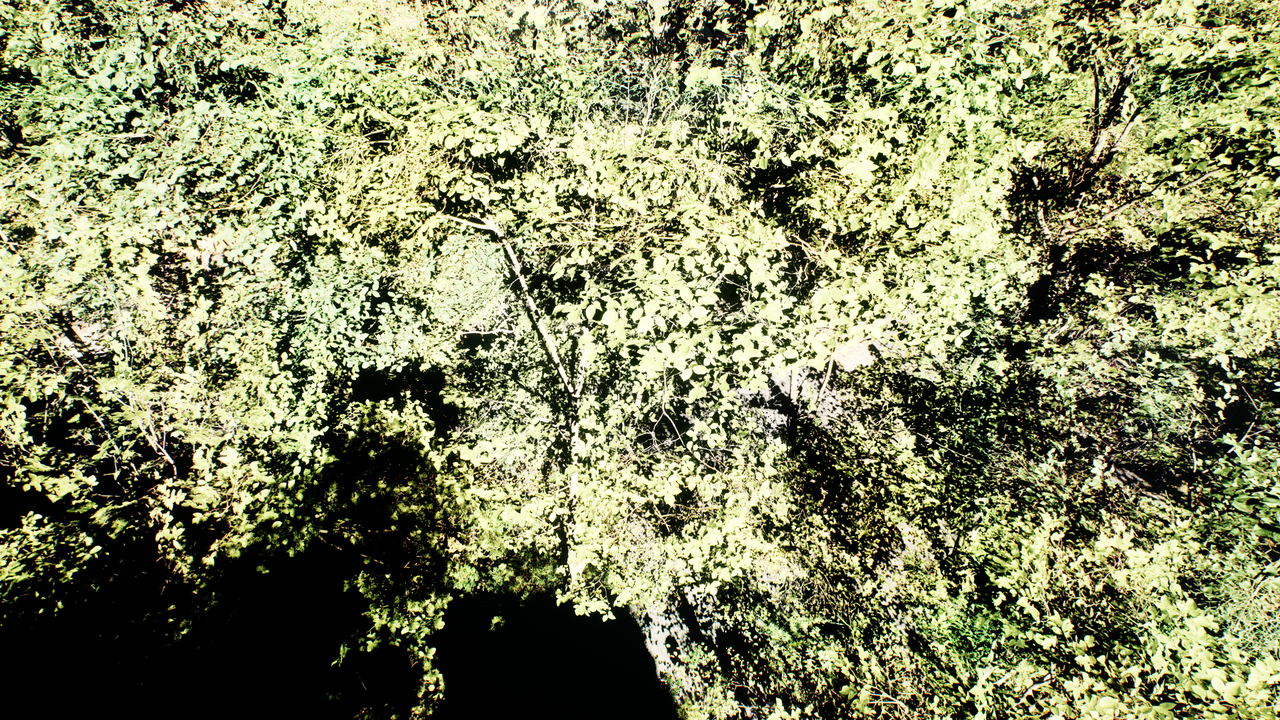
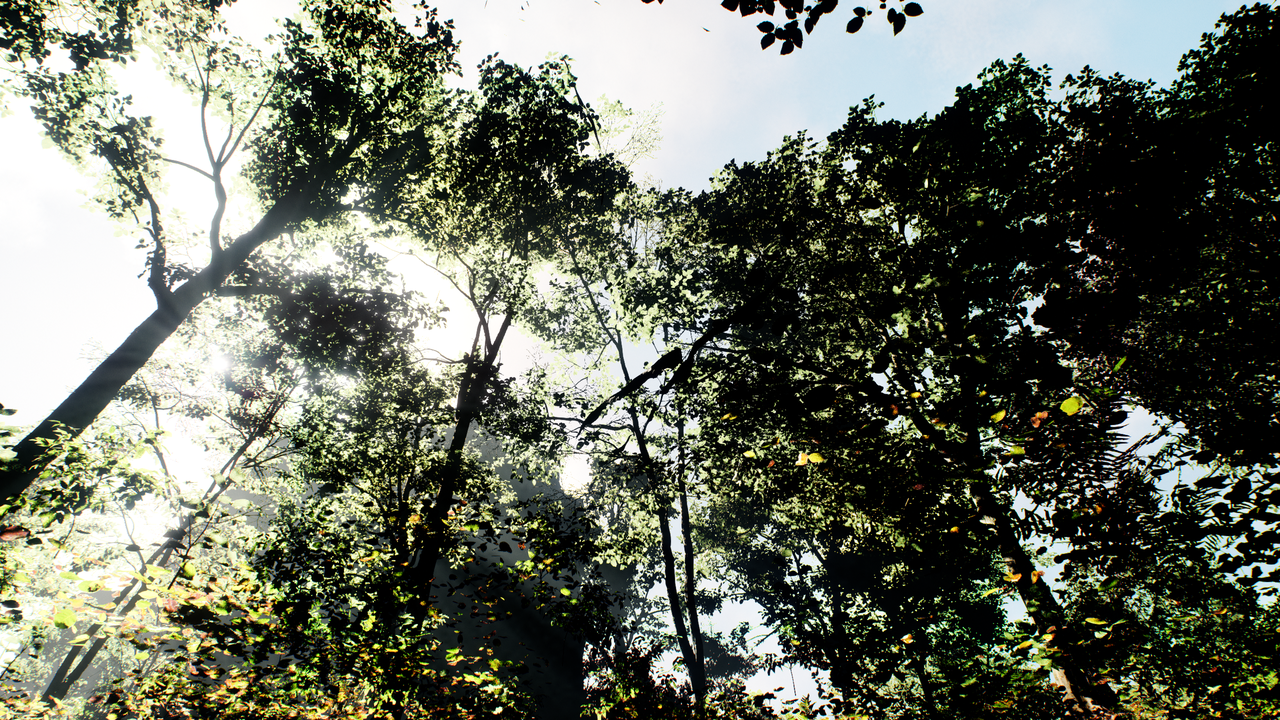
Right RGB / right 3 files · 5.7 MB
Right-camera RGB renderings forming the stereo pair (63 mm baseline).
All 3 files
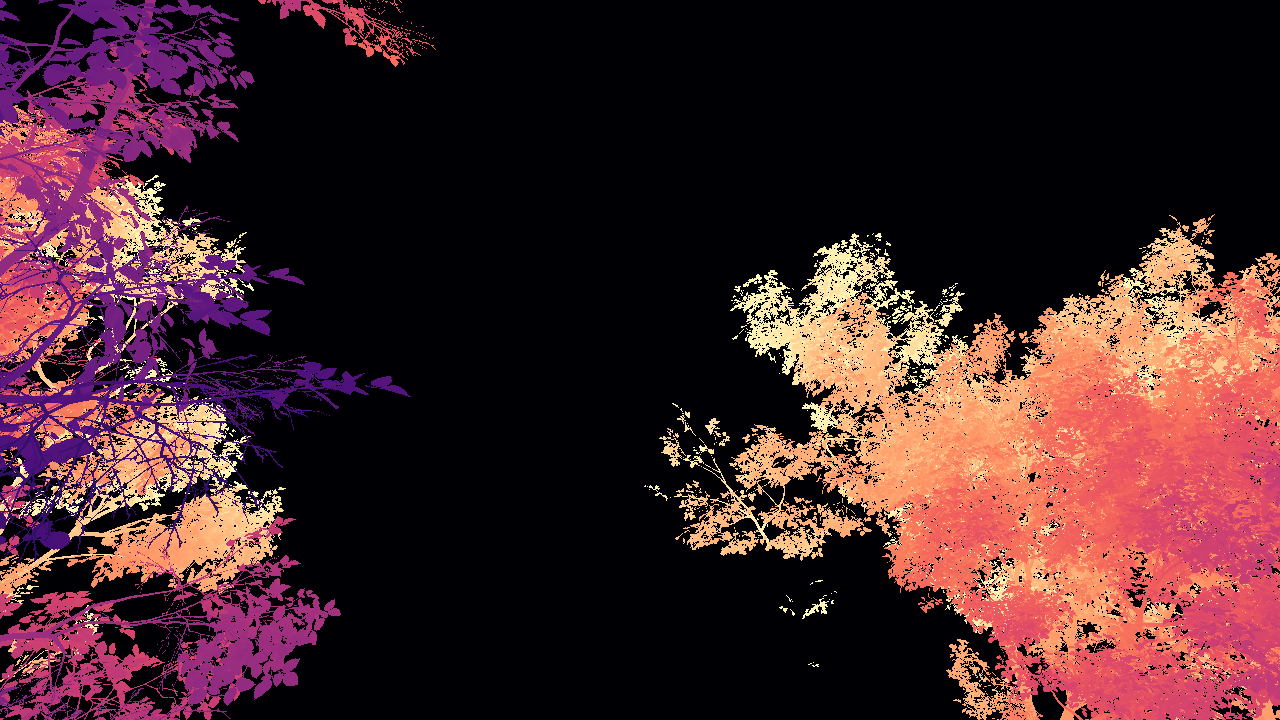
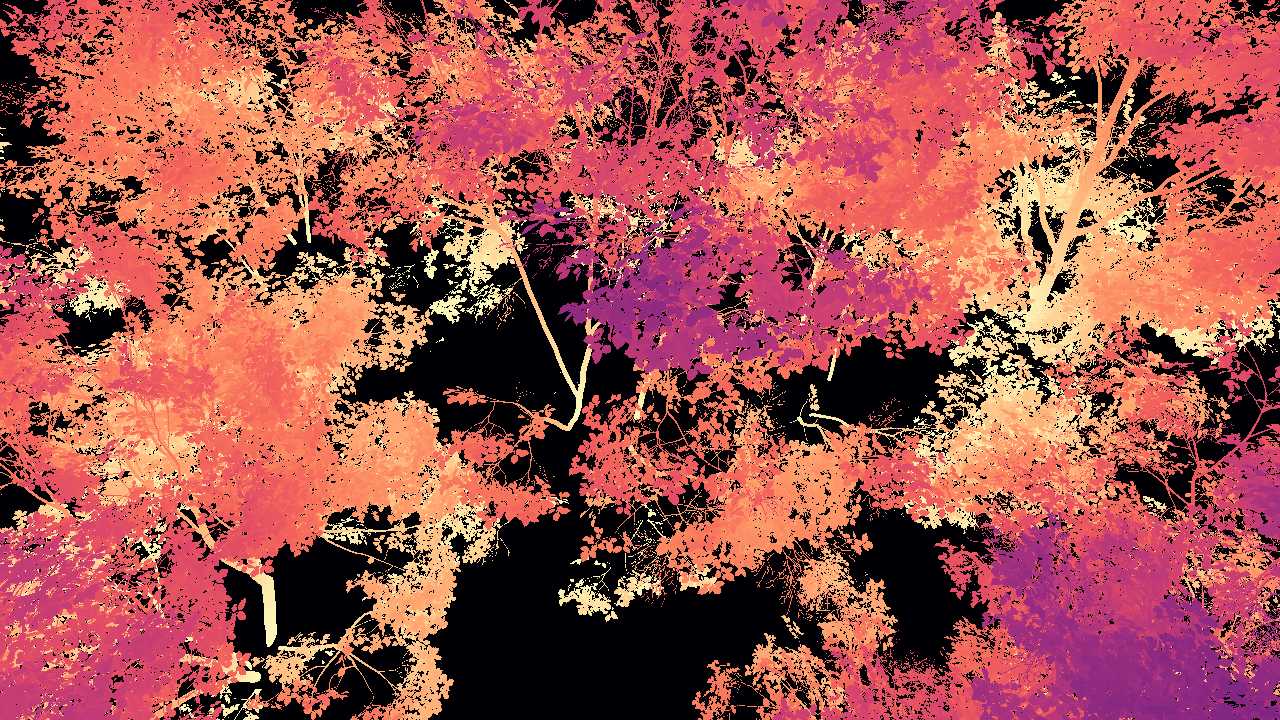
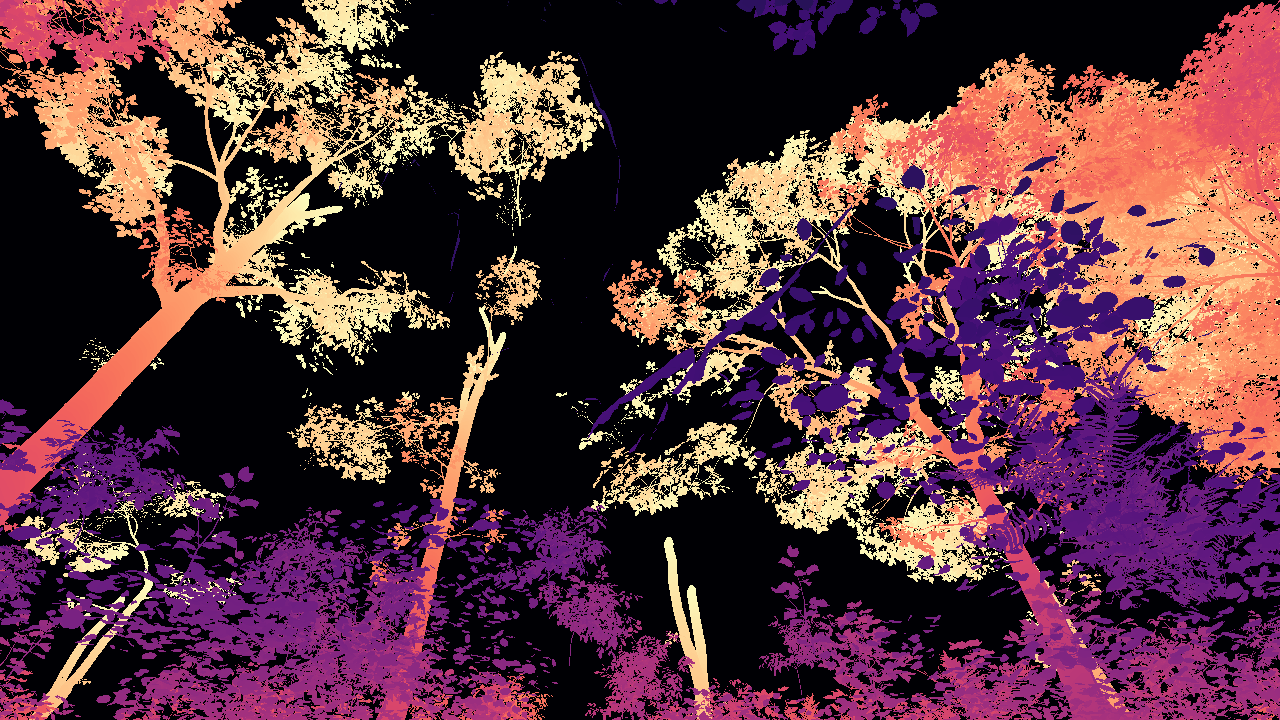
Left Depth / left_depth 6 files · 3.6 MB
Per-pixel metric depth. EXR/NPY and a 16-bit millimetre PNG for ground truth, *_vis.png for preview.
Right Depth / right_depth 6 files · 3.6 MB
Per-pixel metric depth for the right camera.
Left Disparity / left_disparity 6 files · 2.3 MB
Disparity in pixels (left frame), 16-bit PNG and float NPY.
Right Disparity / right_disparity 6 files · 2.3 MB
Disparity in pixels (right frame).
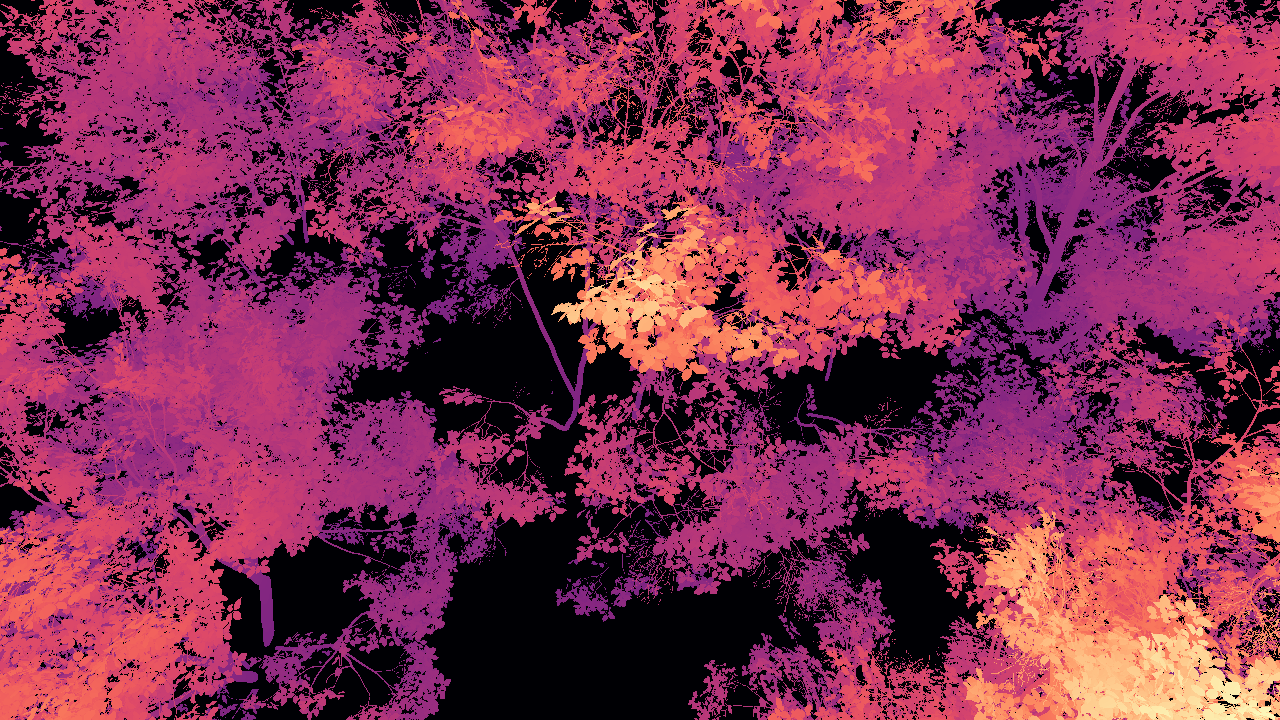
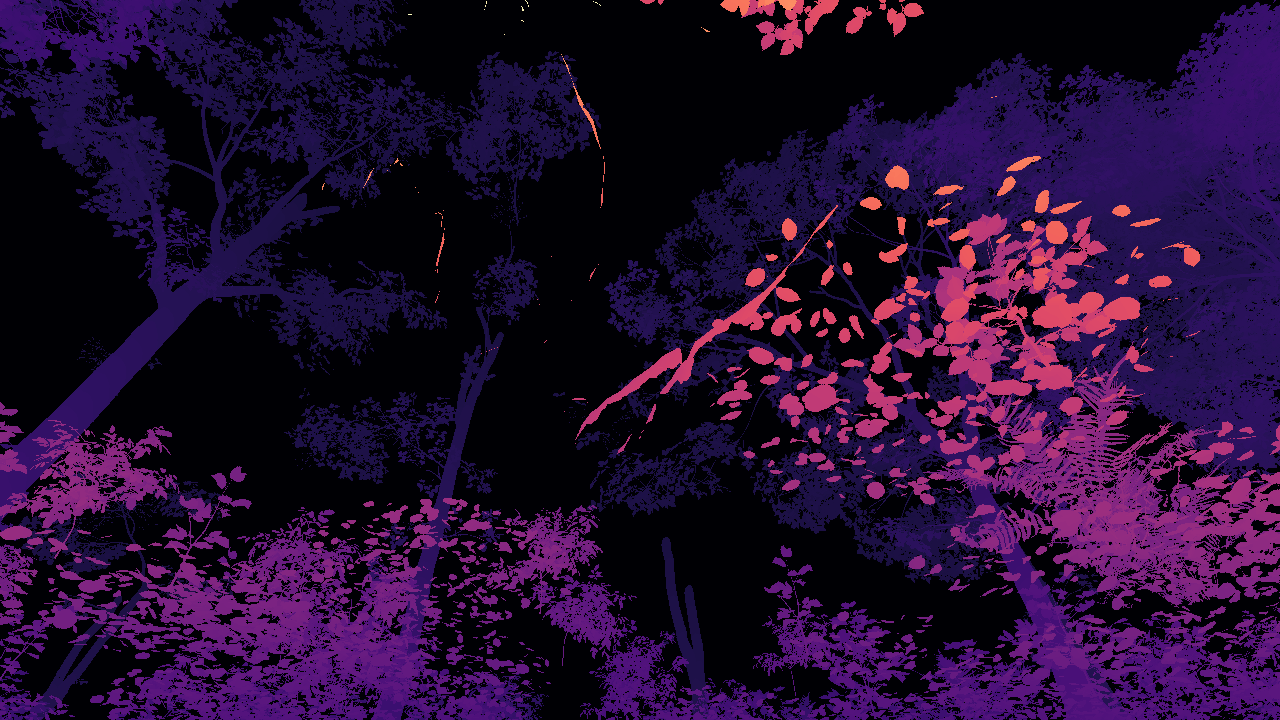
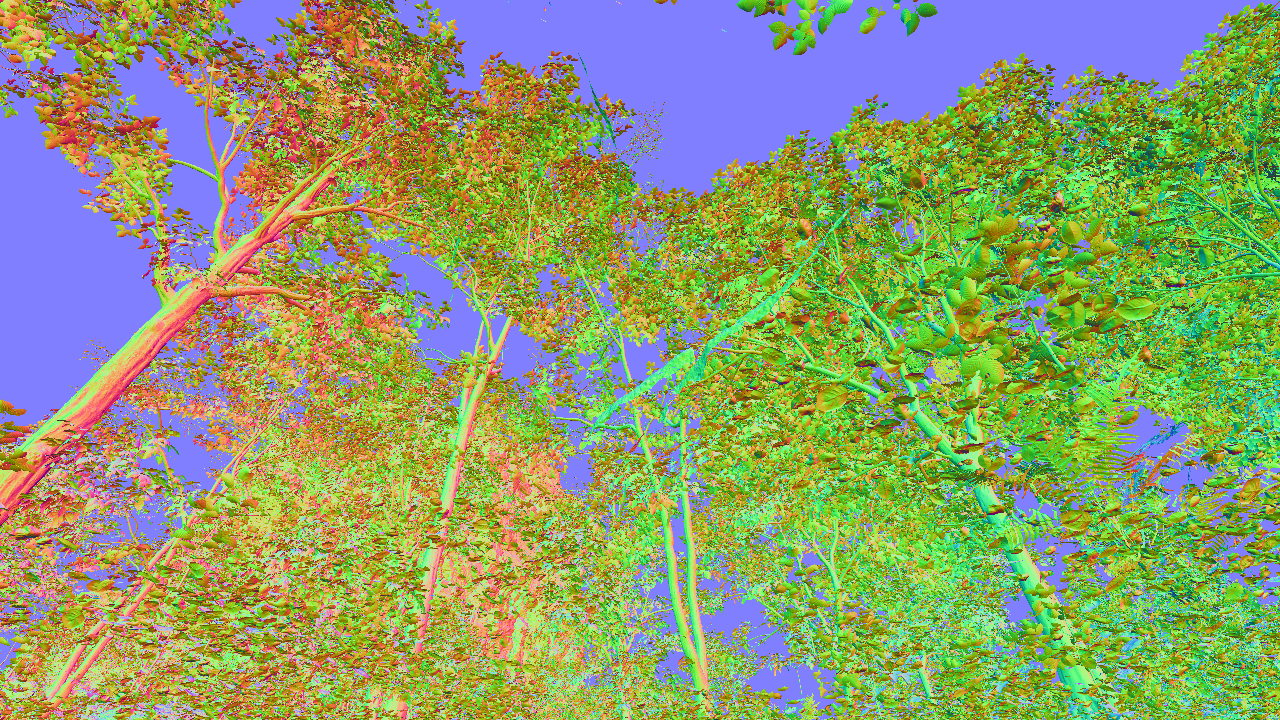
Left Surface Normals / left_normal 3 files · 6.4 MB
World-space surface normals. EXR/NPY for ground-truth, *_vis.png for preview.
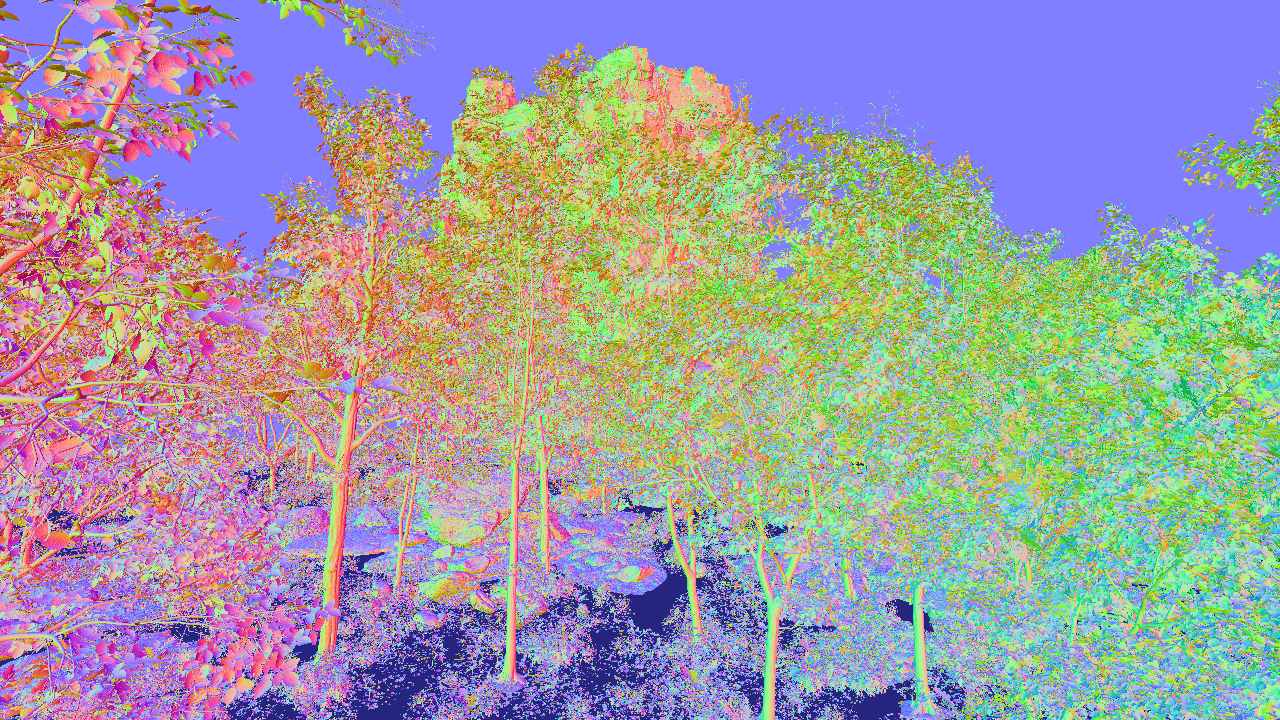
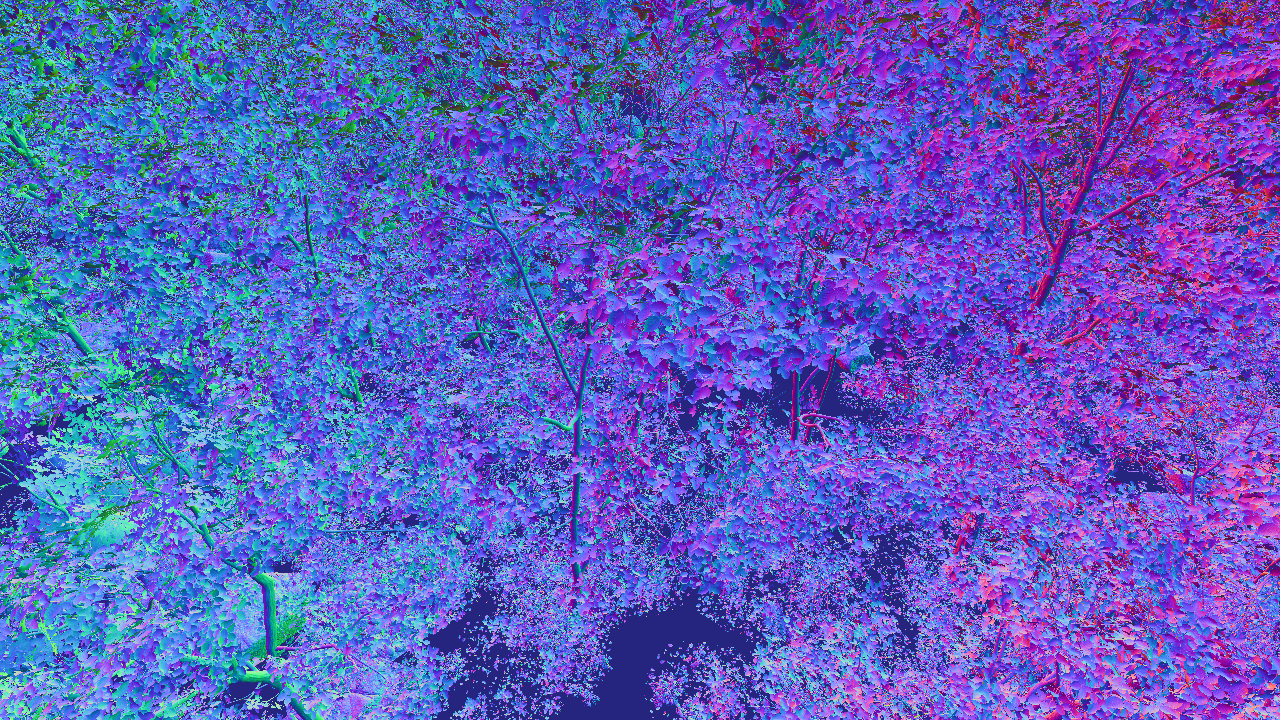
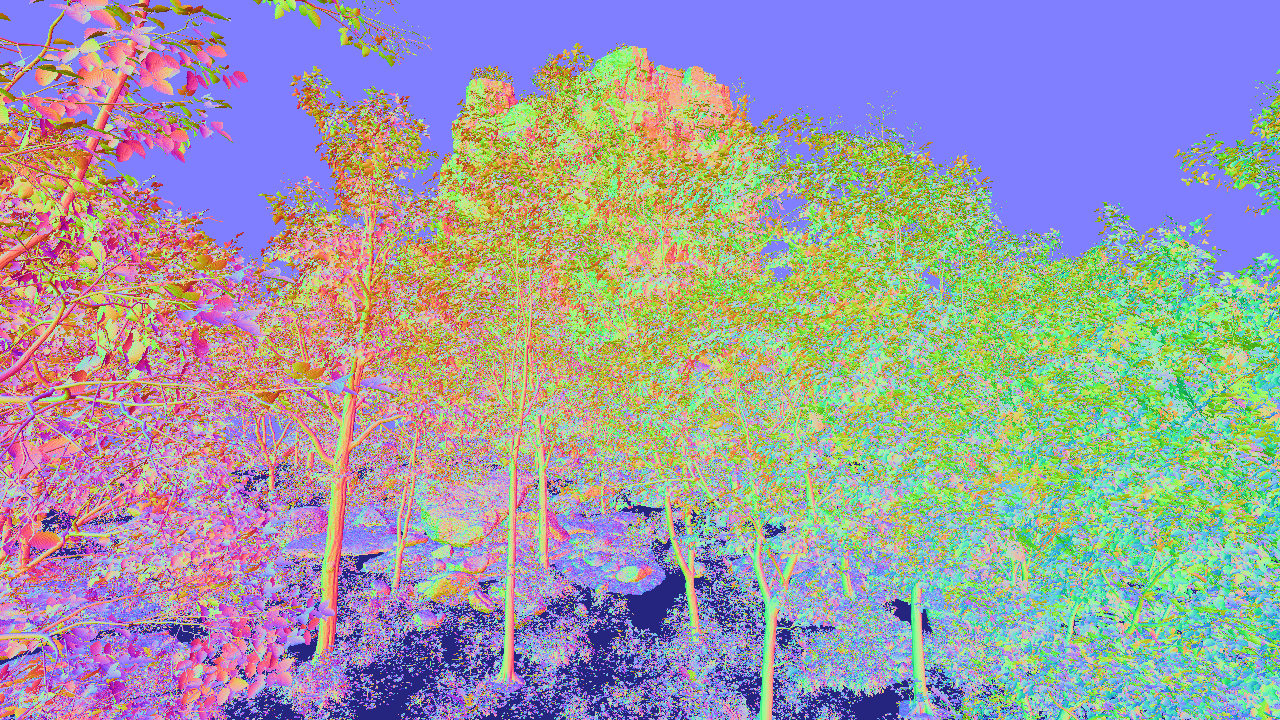
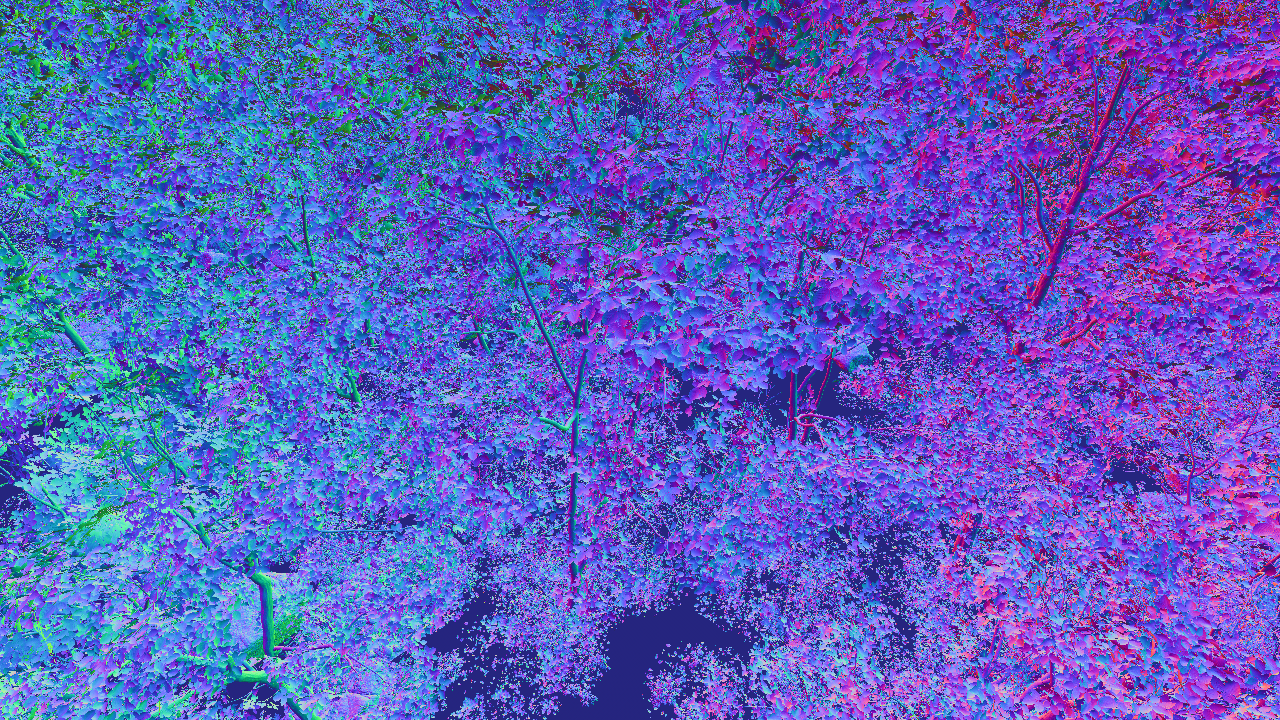
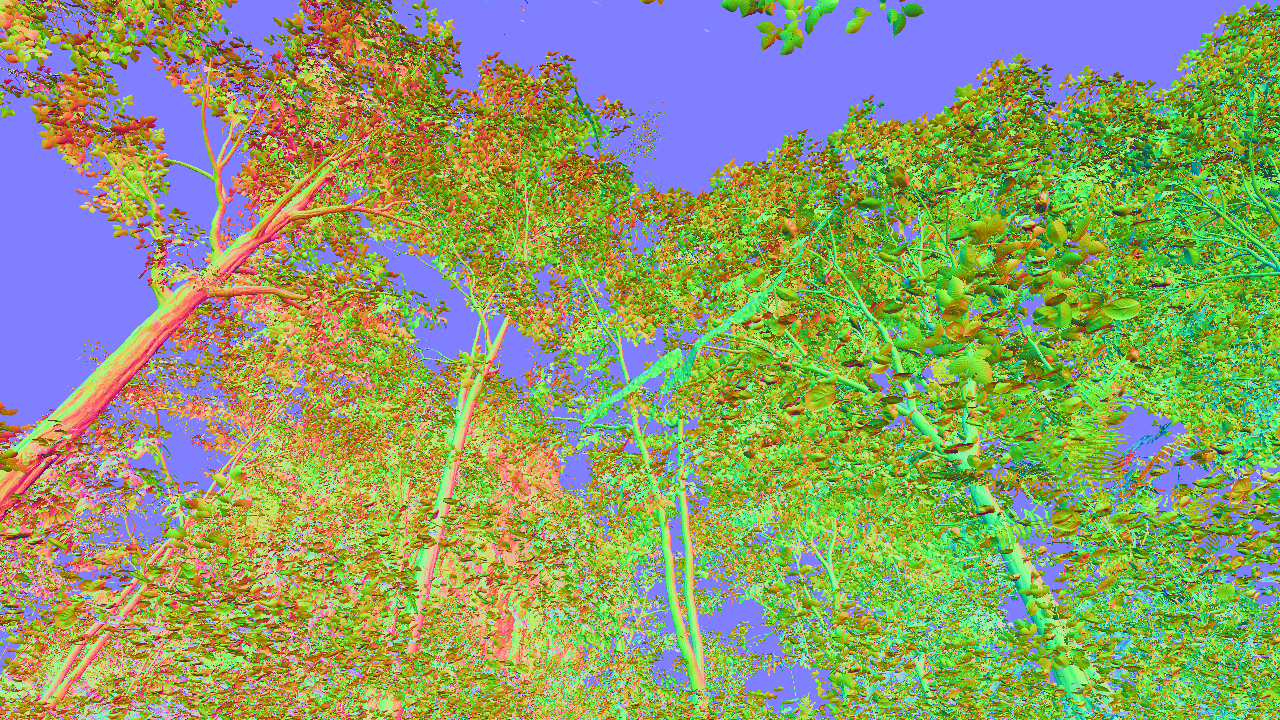
Right Surface Normals / right_normal 3 files · 6.4 MB
World-space surface normals for the right view.
Left Instance Segmentation / left_seg 12 files · 6.1 MB
Per-instance segmentation: colourised PNG, integer ID PNG, target mask and overlay.


All 12 files
Right Instance Segmentation / right_seg 12 files · 6.1 MB
Per-instance segmentation for the right view.


All 12 files
Left Semantic Classes / left_class 6 files · 692 KB
Semantic class map: *_class.png holds the integer class per pixel, *_class_color.png is the colourised preview.


Right Semantic Classes / right_class 6 files · 692 KB
Semantic class map for the right view.


Left Detection Labels / left_labels 6 files · 74 KB
YOLO annotations for the target tree: normalised polygons in *_labels.txt, boxes in *_labels_bbox.txt.
Binary format — no browser-renderable preview. The files are listed below.
Right Detection Labels / right_labels 6 files · 81 KB
YOLO polygons and boxes for the right view.
Binary format — no browser-renderable preview. The files are listed below.
Point Clouds / pointcloud 4 files · 16.2 MB
Dense point clouds (.ply), per frame and/or merged across the orbit, in raw and coloured variants.
Binary format — no browser-renderable preview. The files are listed below.