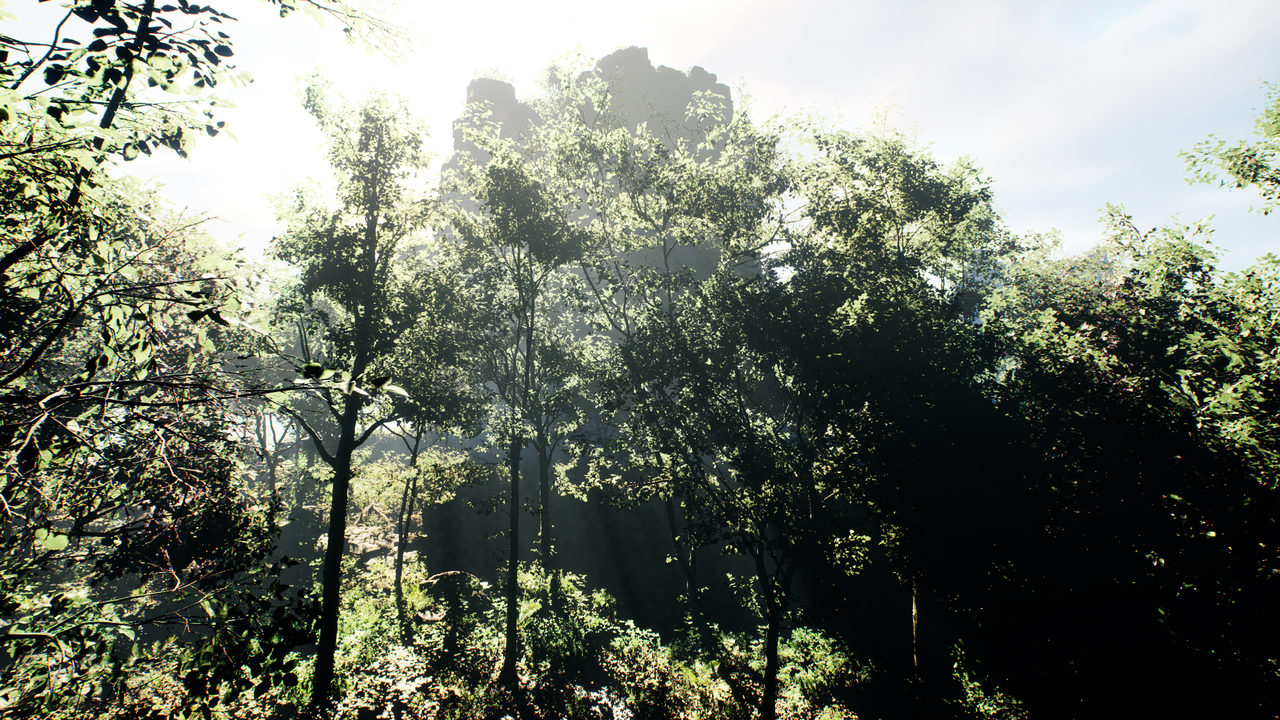
Left RGB left
The reference view — a physically based rendering of the target tree, shot with the simulated ZED Mini left sensor.
- 002_horizontal_02.png — preview
example_720, tree390
These are 3 frames from the benchmark, shown modality by modality. Each frame was rendered from one instant of the same virtual stereo rig, so its depth, disparity, normals and segmentation are all pixel-aligned with its RGB.
The full release repeats this for 48 viewpoints per tree across a 356.0° orbit; 3 frames and 88 files (66.0 MB) are published here as a sample.
Two views of the same scene, 63.0 mm apart. The horizontal shift between them is exactly what the disparity map below encodes.
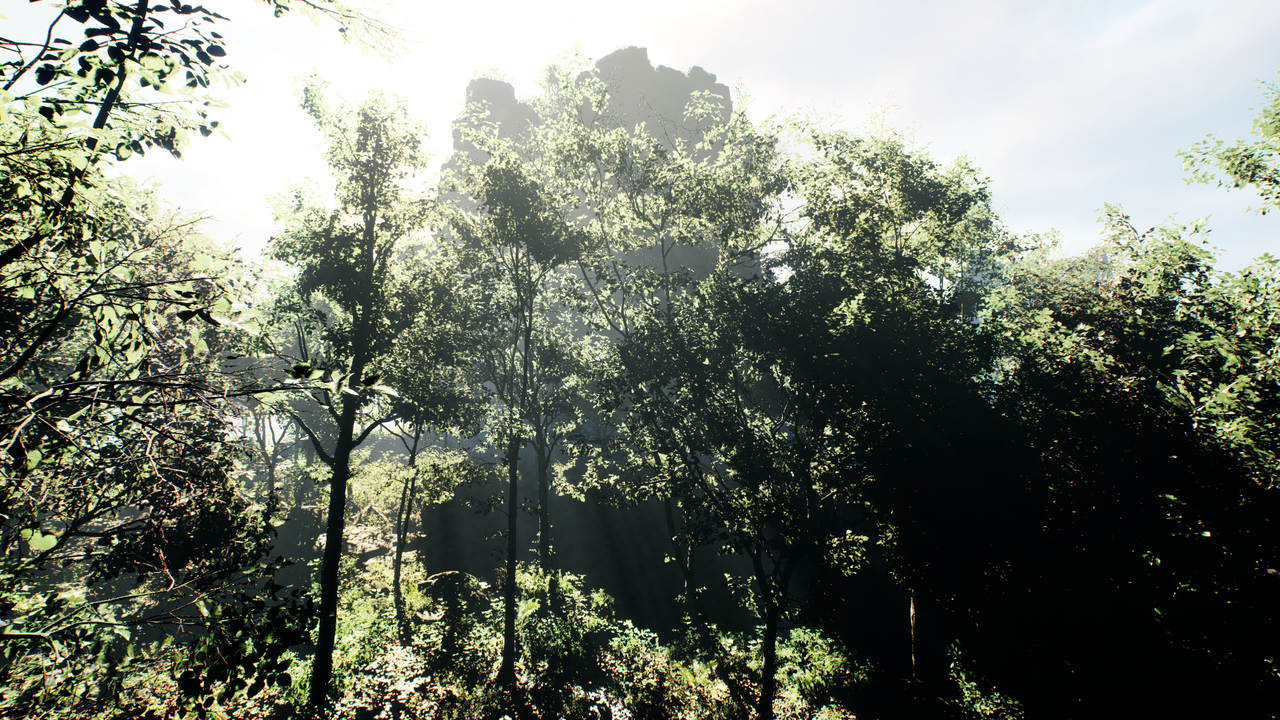
The reference view — a physically based rendering of the target tree, shot with the simulated ZED Mini left sensor.
The matching right-sensor frame. Together with the left frame this forms the rectified stereo pair at a 63 mm baseline.
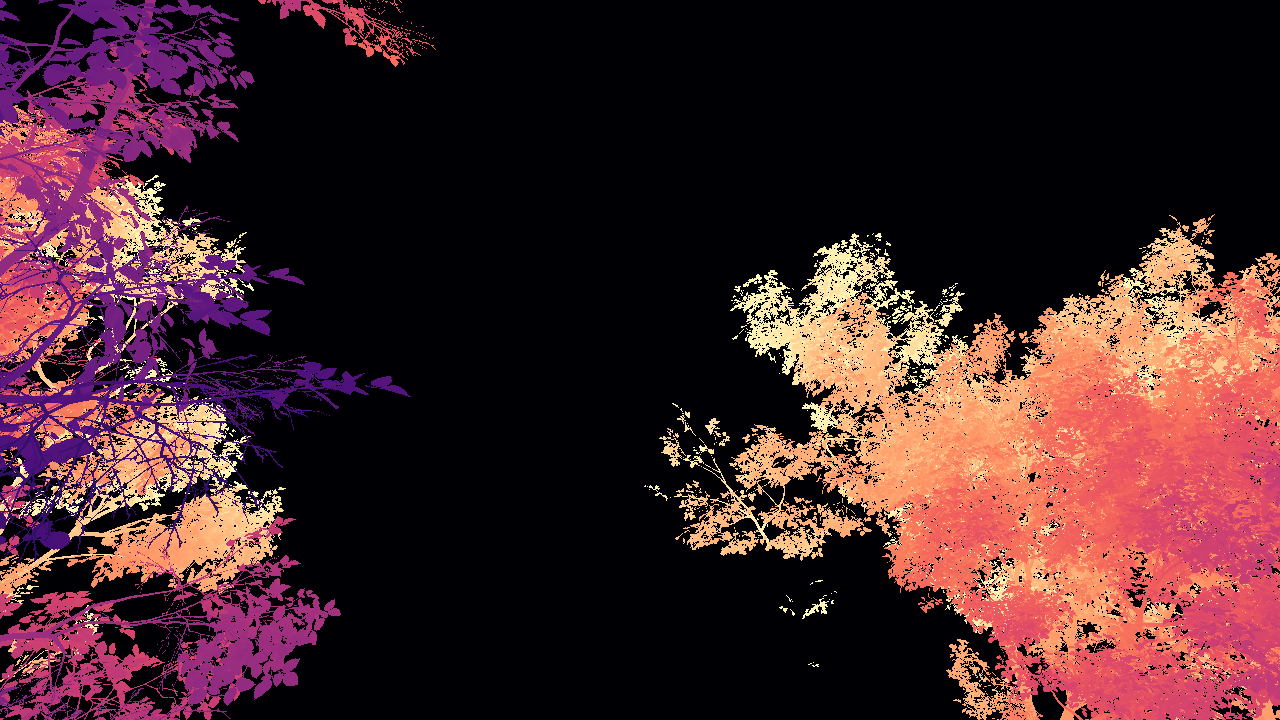
Per-pixel metric depth in metres. The preview is a colourised visualisation; the companion files carry the raw values.
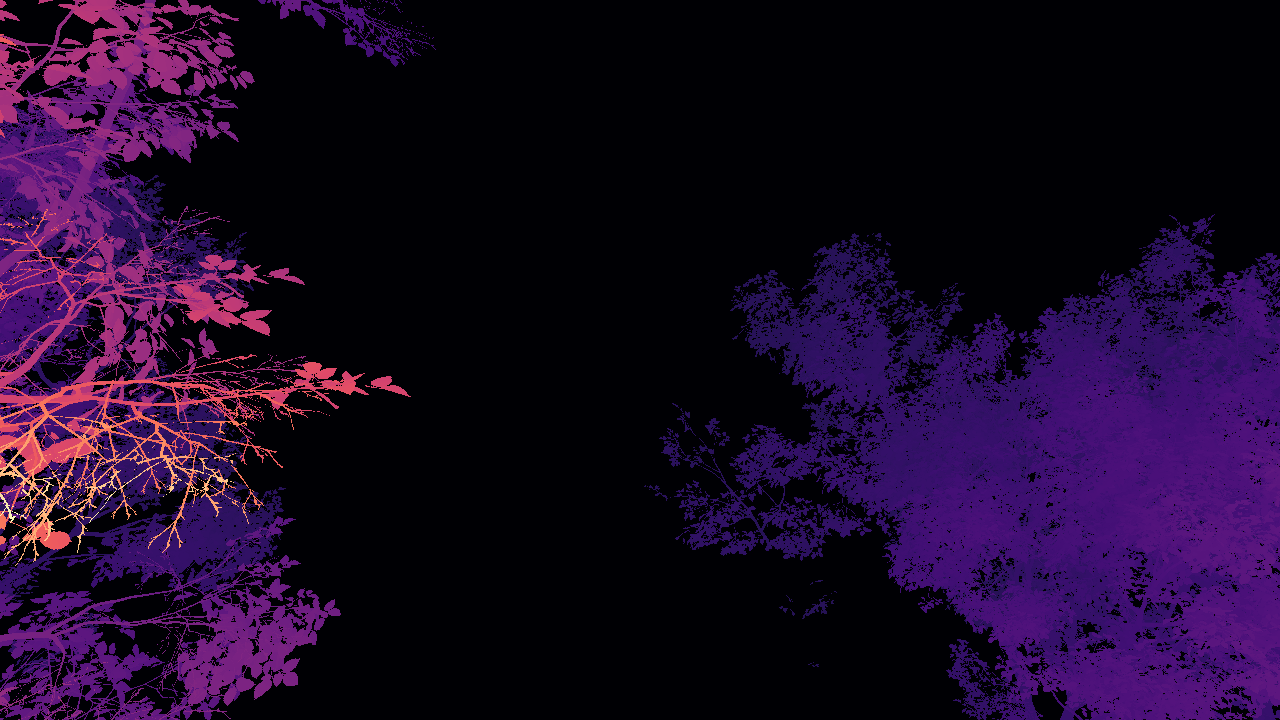
Stereo disparity in pixels, supplied as a 16-bit PNG alongside this preview.
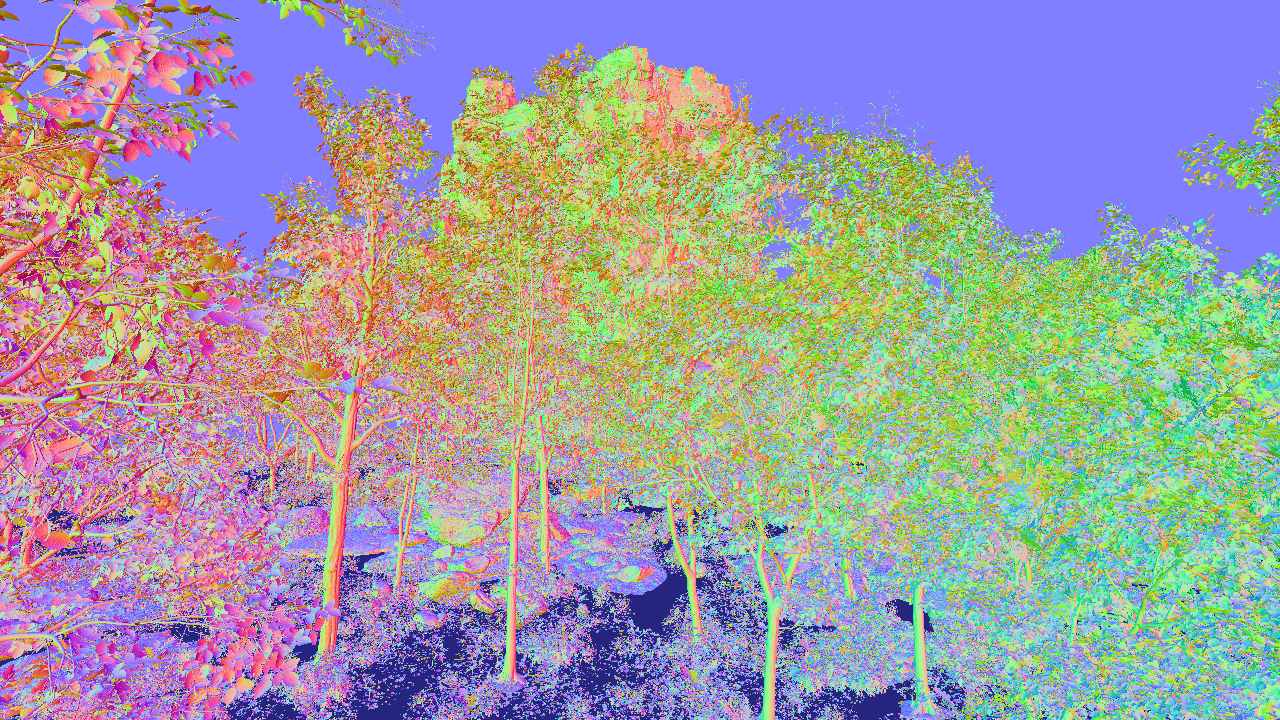
World-space surface normals encoded as RGB. Useful for shape-from-shading and geometry-consistency losses.

Per-instance masks that separate the target tree from the surrounding canopy, with an integer ID map beside them.

Every pixel labelled with one of eleven scene classes — tree, sapling, shrub, fern, groundcover, leaf litter, rock, ground, deadwood and the rest — as an integer map plus this preview.
YOLO annotations for the target tree: one normalised polygon per frame in *_labels.txt and the matching axis-aligned box in *_labels_bbox.txt, under the single class 'tree'.
Each view is also back-projected into a dense point cloud in PLY format — the left and right clouds share a coordinate frame, so they can be merged directly or used to validate a reconstruction.
Disparity d relates to depth Z by
Z = fx · B / d, with
fx = 640.0 px and
B = 63.0 mm.
The published files are named by their index in the release
(0_left.png), so what you see here is what you will find in
the download. The orbit position each one came from is below.
| ID | Frame | Ring | Elevation | Capture index |
|---|---|---|---|---|
002_horizontal_02 |
horizontal | 0° | 2 | |
026_up45_10 |
up45 | 45° | 26 | |
035_down45_03 |
down45 | -45° | 35 |
Alongside the per-instance masks, every pixel in this release carries a
semantic class. The *_class_class.png map stores the integer
index below; *_class_class_color.png is only a preview.
The detection labels are separate and much simpler: a single class,
tree (class 0),
with one normalised polygon per frame for the target tree in
*_labels.txt and the matching axis-aligned box in
*_labels_bbox.txt.
20 tree instances appear in this
capture's segmentation, of which
tree390 is the orbit target.
Every modality above repeats across the complete orbit for each published tree.